This article provides a detailed guide on how to use the configuration software for the Y Series Closed-Loop Driver.
(The Y Series Closed-Loop Driver is available in two hardware versions: V1.0 and V2.0. Both versions are compatible with the new software, but their connection methods to a PC differ slightly. Each version is explained separately below.)
New version software download link: Y_Series_Stepper_Driver_Debug_Software_V1.2.7.zip
V1.0:
Required items: driver, power supply, configuration tool (setting unit), and driver software. (Connect the motor as needed.) The CL57Y is used as an example here:
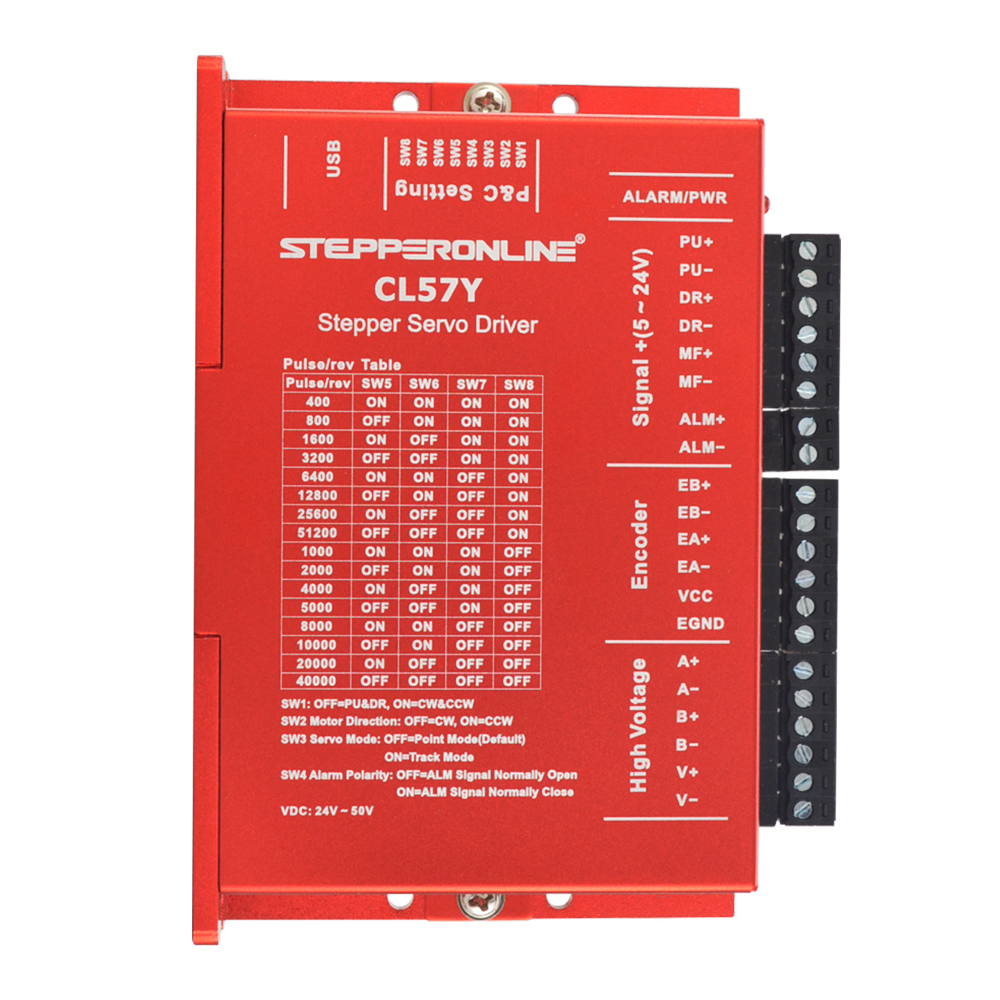
Use the two cables included with the Y-USB-CL configuration tool and connect them in the following order: Driver → Configuration Tool → PC.
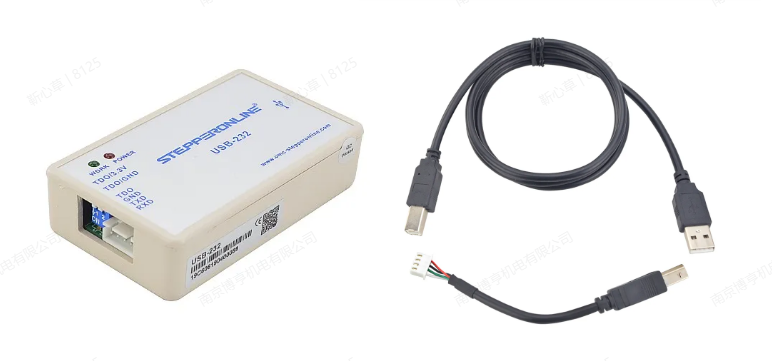
Y-USB-CL configuration tool product link: https://www.omc-stepperonline.com/handheld-intelligent-setting-unit-for-closed-loop-driver-y-usb-cl
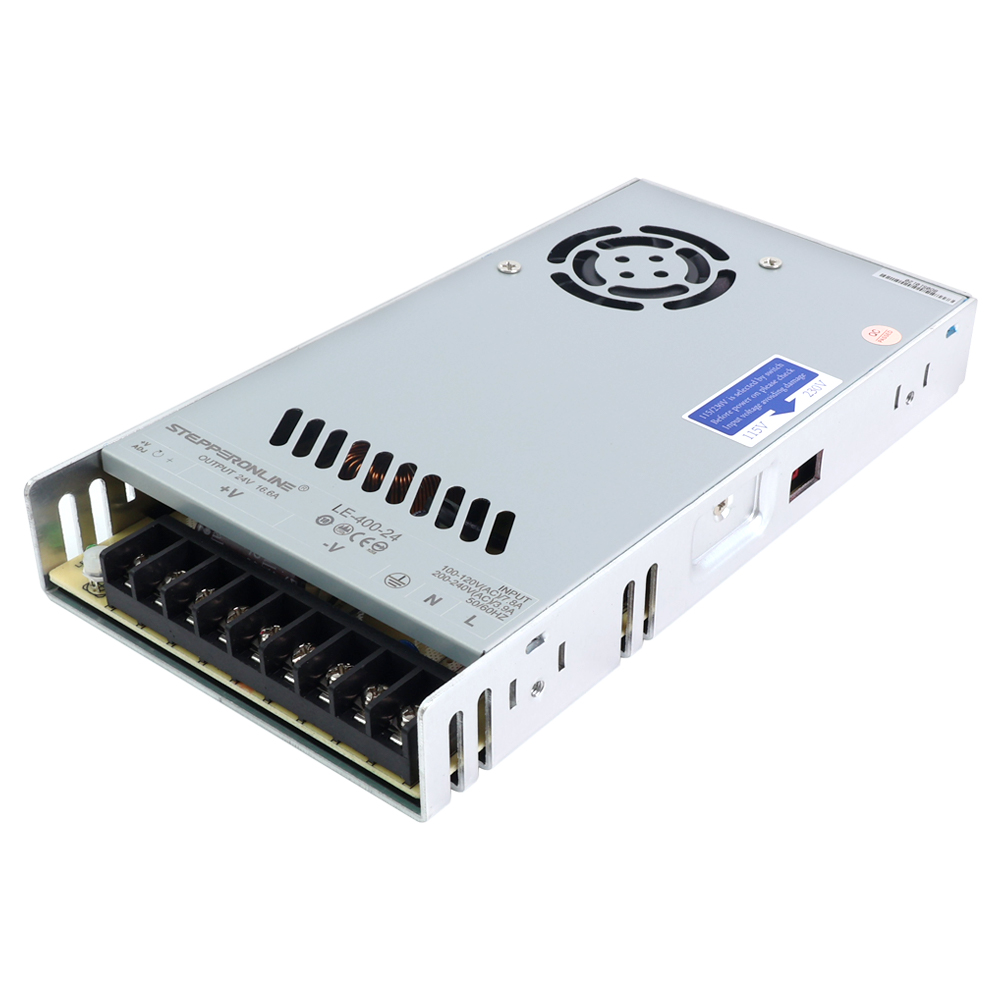
Use a DC power supply to power the driver. (Note: The power supply voltage must be within the driver's input range. For example, the CL57Y input voltage range is 24–50 VDC, so the power supply output must fall within this range.) Connect the V+ terminal of the power supply to the V+ port of the driver, and the V− terminal to the V− port. After powering on, the indicator lights on both the driver and the configuration tool will illuminate.
V2.0:
Required items: driver, power supply, RS232 configuration cable, and driver software. (Connect the motor as needed.) The CL57Y-V20 is used as an example here:
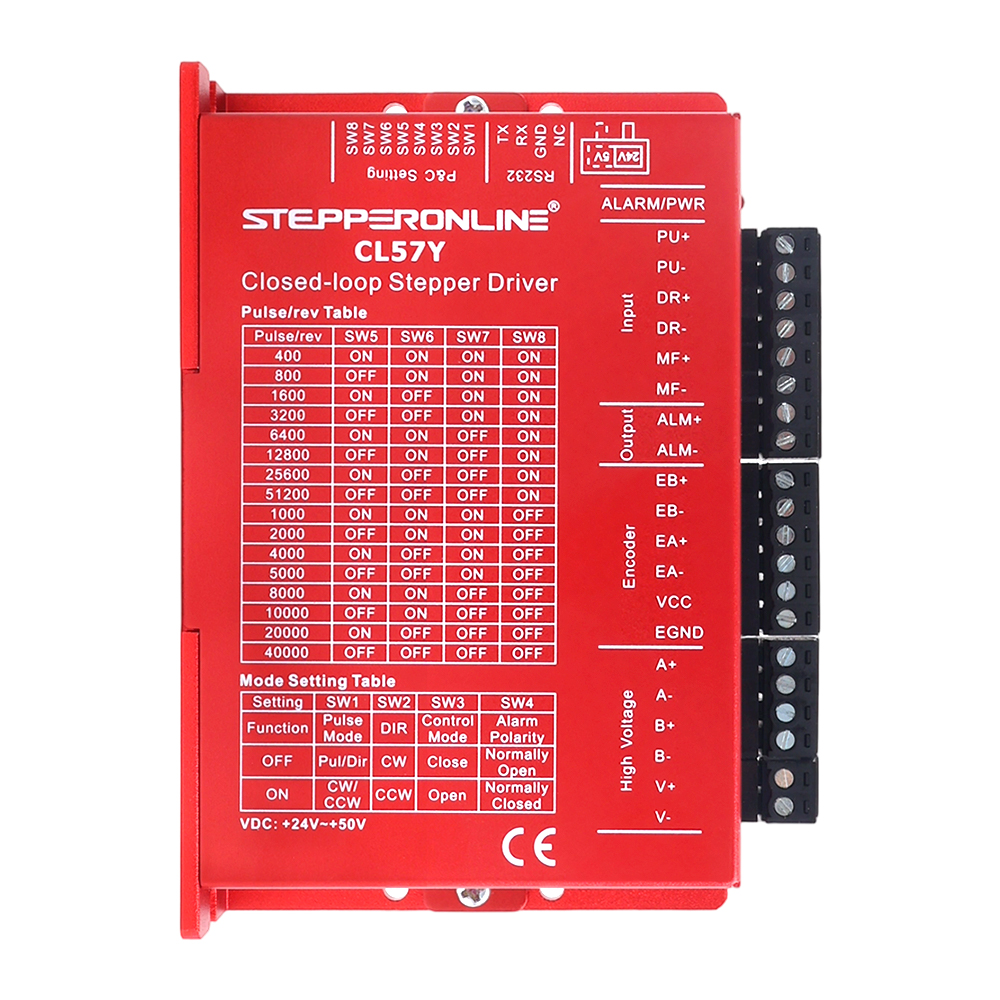
Use the CABLE-PC-2 configuration cable included with the driver and connect it in the following order: Driver → Configuration Cable → PC. (If your computer does not have a DB9 serial port, we recommend using this USB-to-RS232 adapter: https://www.omc-stepperonline.com/usb-2-0-to-serial-rs232-adapter-with-1m-cable-converter-c006)
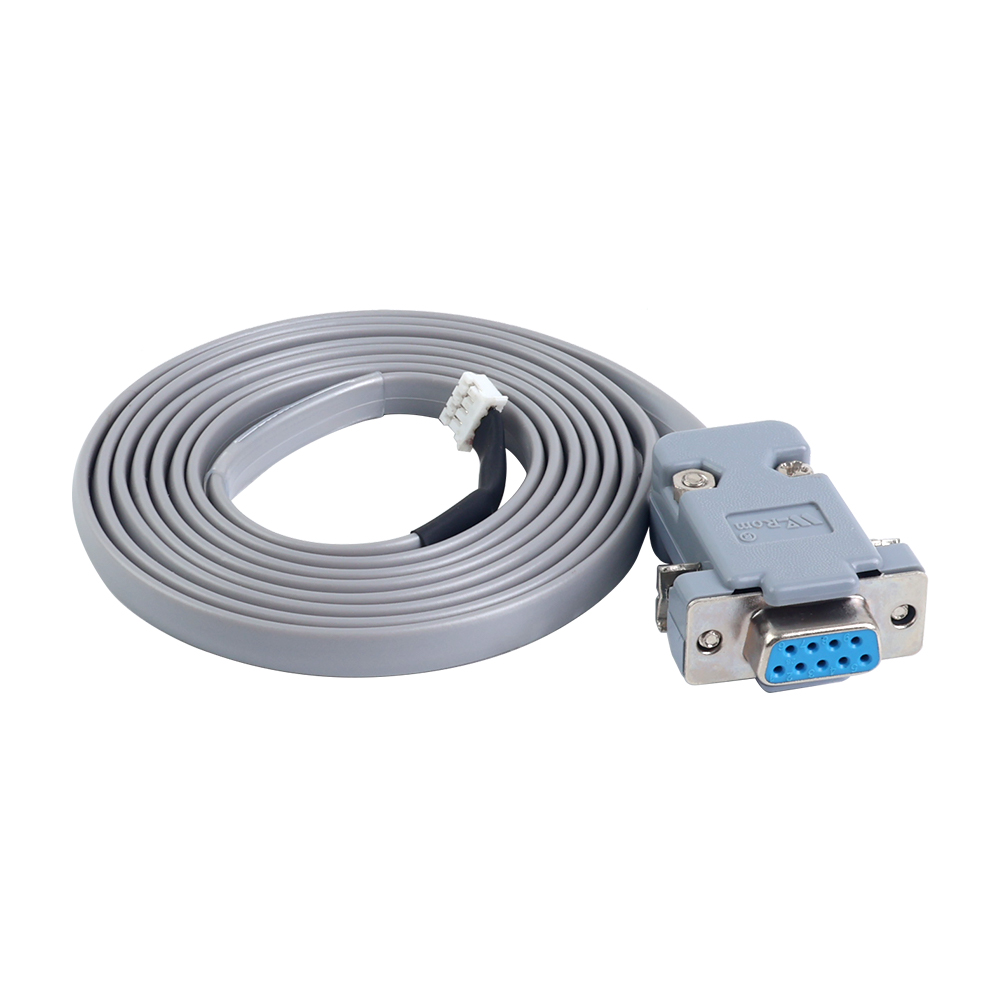
Use a DC power supply to power the driver. (Note: The power supply voltage must be within the driver's input range. For example, the CL57Y input voltage range is 24–50 VDC, so the power supply output must fall within this range.) Connect the V+ terminal of the power supply to the V+ port of the driver, and the V− terminal to the V− port. After powering on, the indicator light on the driver will illuminate.
For the V2.0 Y Series Closed-Loop Driver, the software connection method has been updated from the V1.0 USB interface to an RS232 interface. A configuration cable is included with the V2.0 driver, so there is no need to purchase a separate configuration tool as required for the V1.0 version. This is the key difference in software connectivity between the two hardware versions.
Below is a detailed guide on how to use the new version of the software.
After downloading the software, select English during installation. Then, click the desktop icon shown below to launch the application:
V1.0:
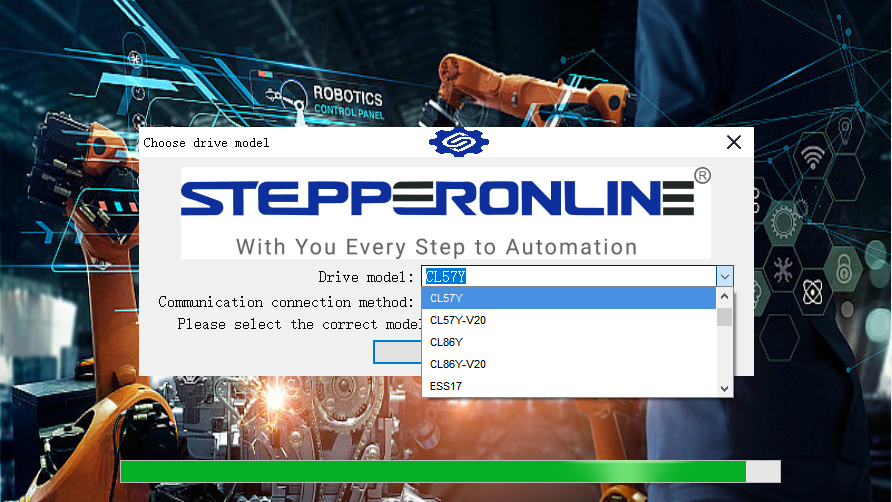
Select the driver model, then click "Confirm" to enter the main software interface:
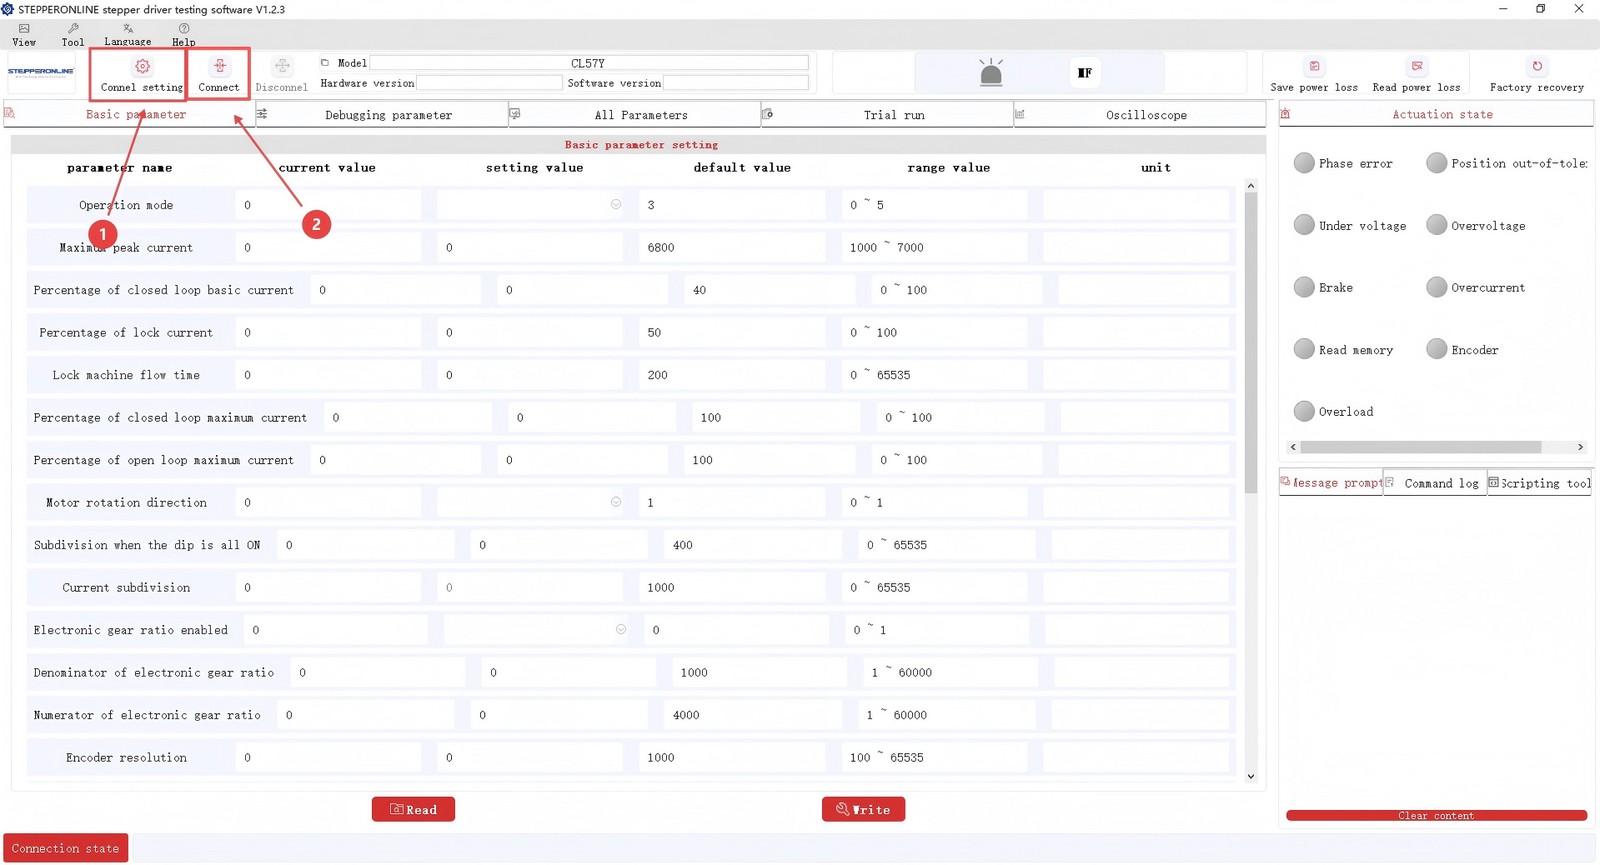
- Click "Connection Settings" to confirm the correct COM port.
- Click "Connect".
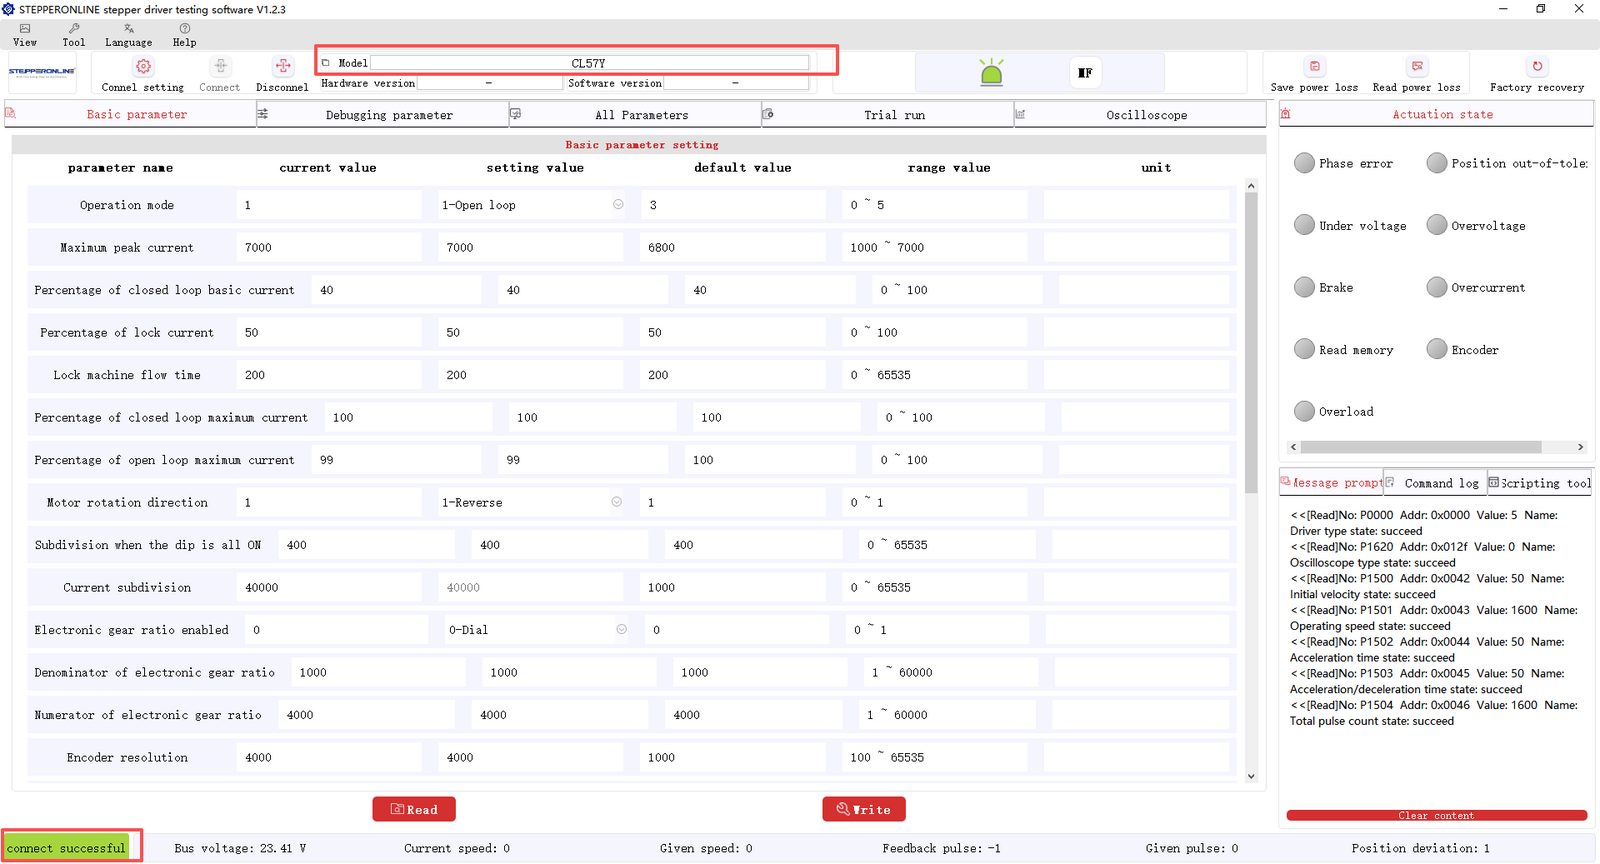
After a successful connection, the driver model will be displayed at the top of the software window, and a green "Connected" indicator will appear in the bottom-left corner.
V2.0:
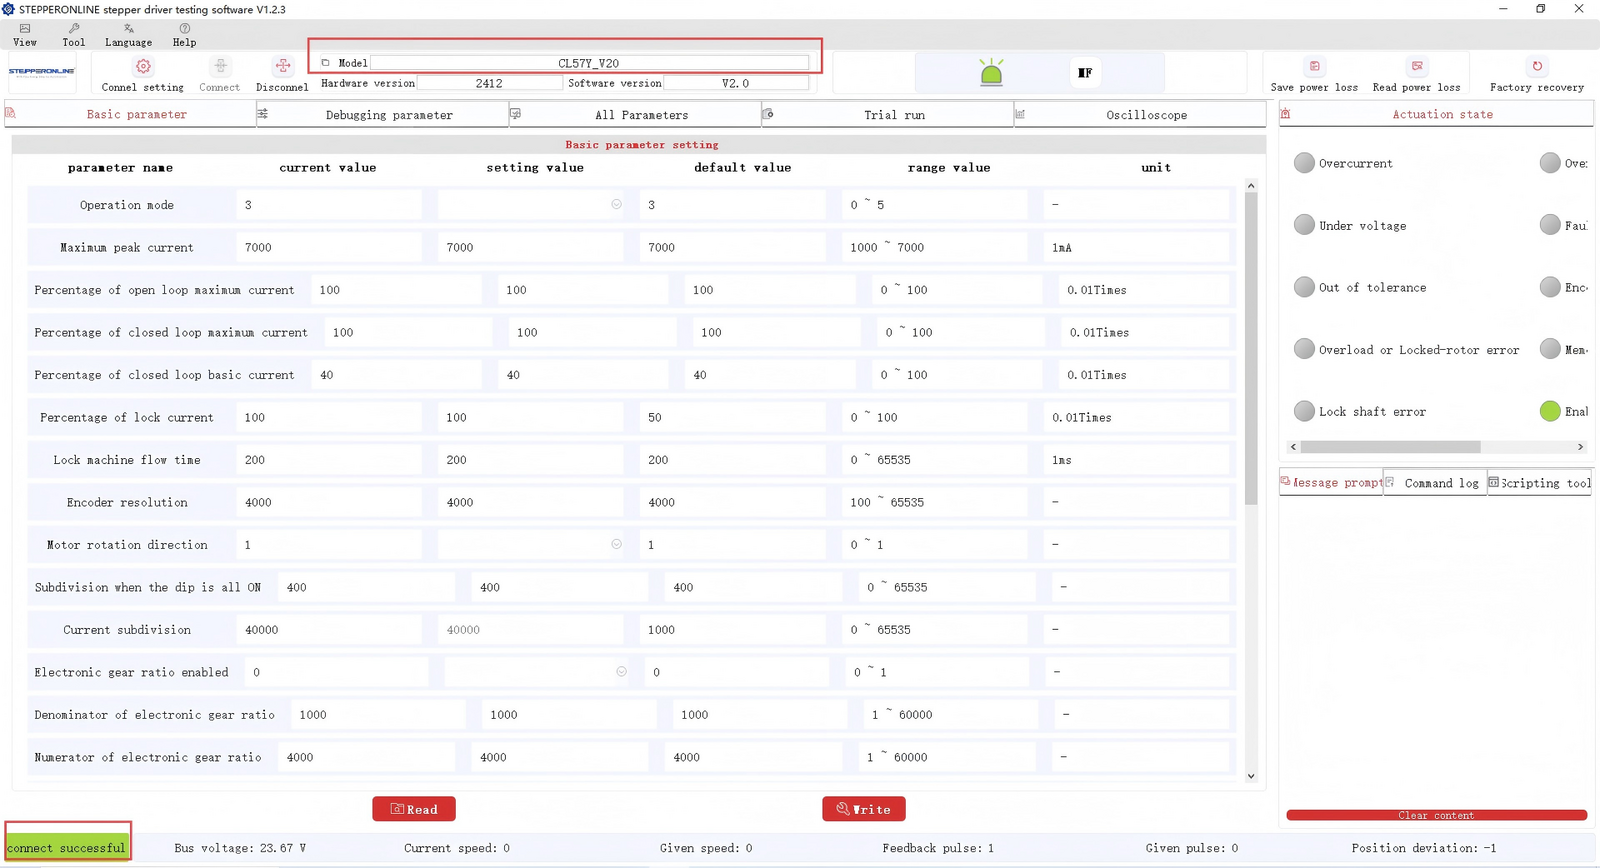
When you open the software, the V2.0 driver will automatically detect the serial port and establish a connection—no manual COM port selection is required.
Click "Read Parameters" to display the driver's current parameter values.
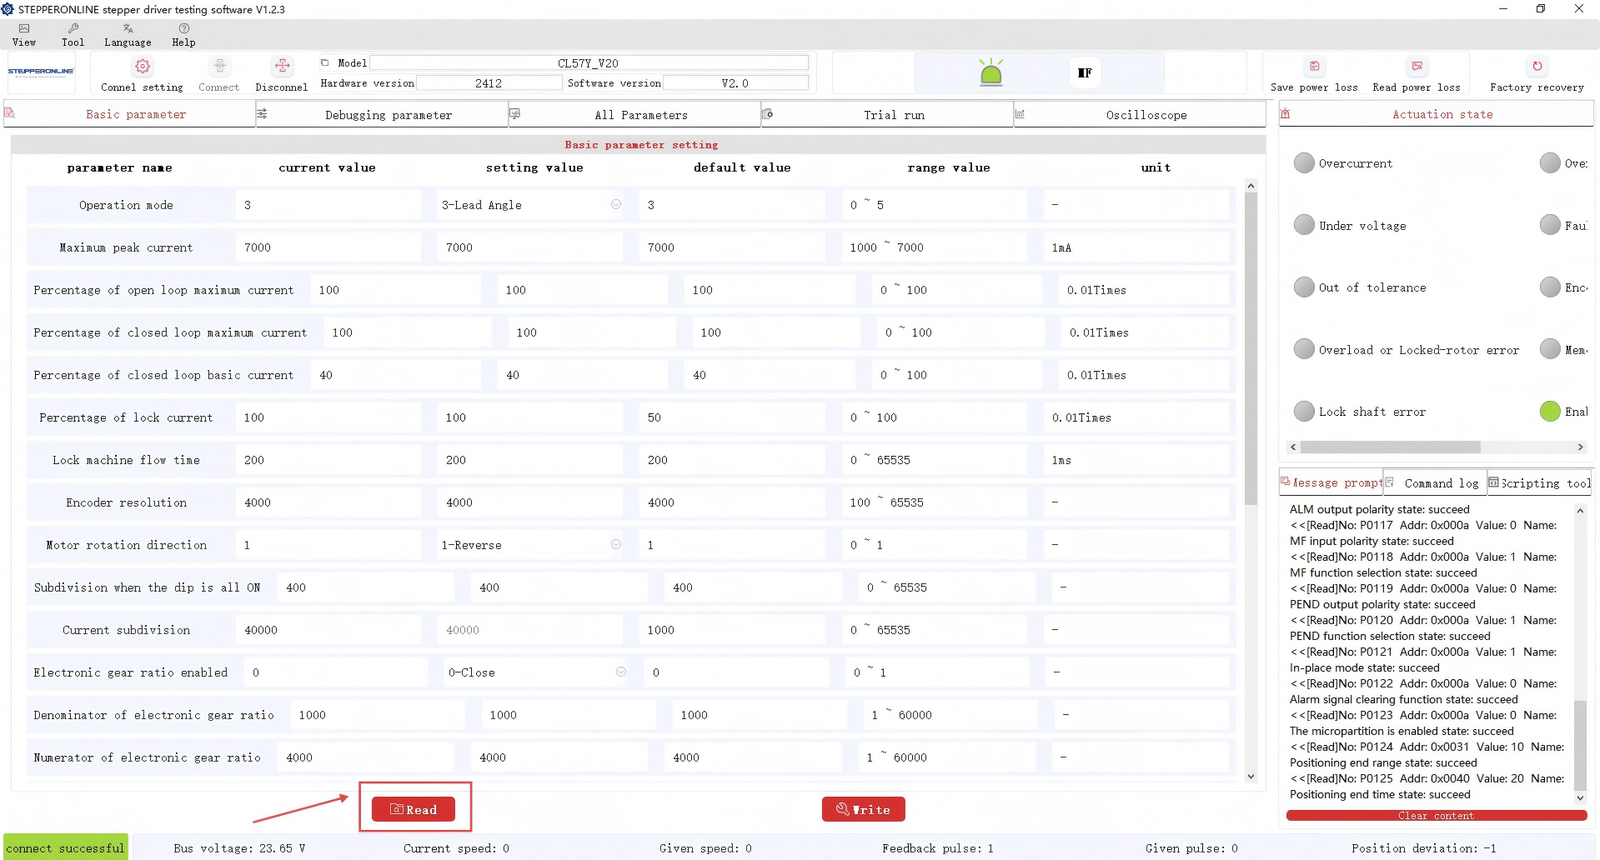
Preparation is now complete. Below is a detailed explanation of each software function.
- Driver Language Switching
The software supports both Chinese and English. Select your preferred language as needed.

- Operating Mode Modification
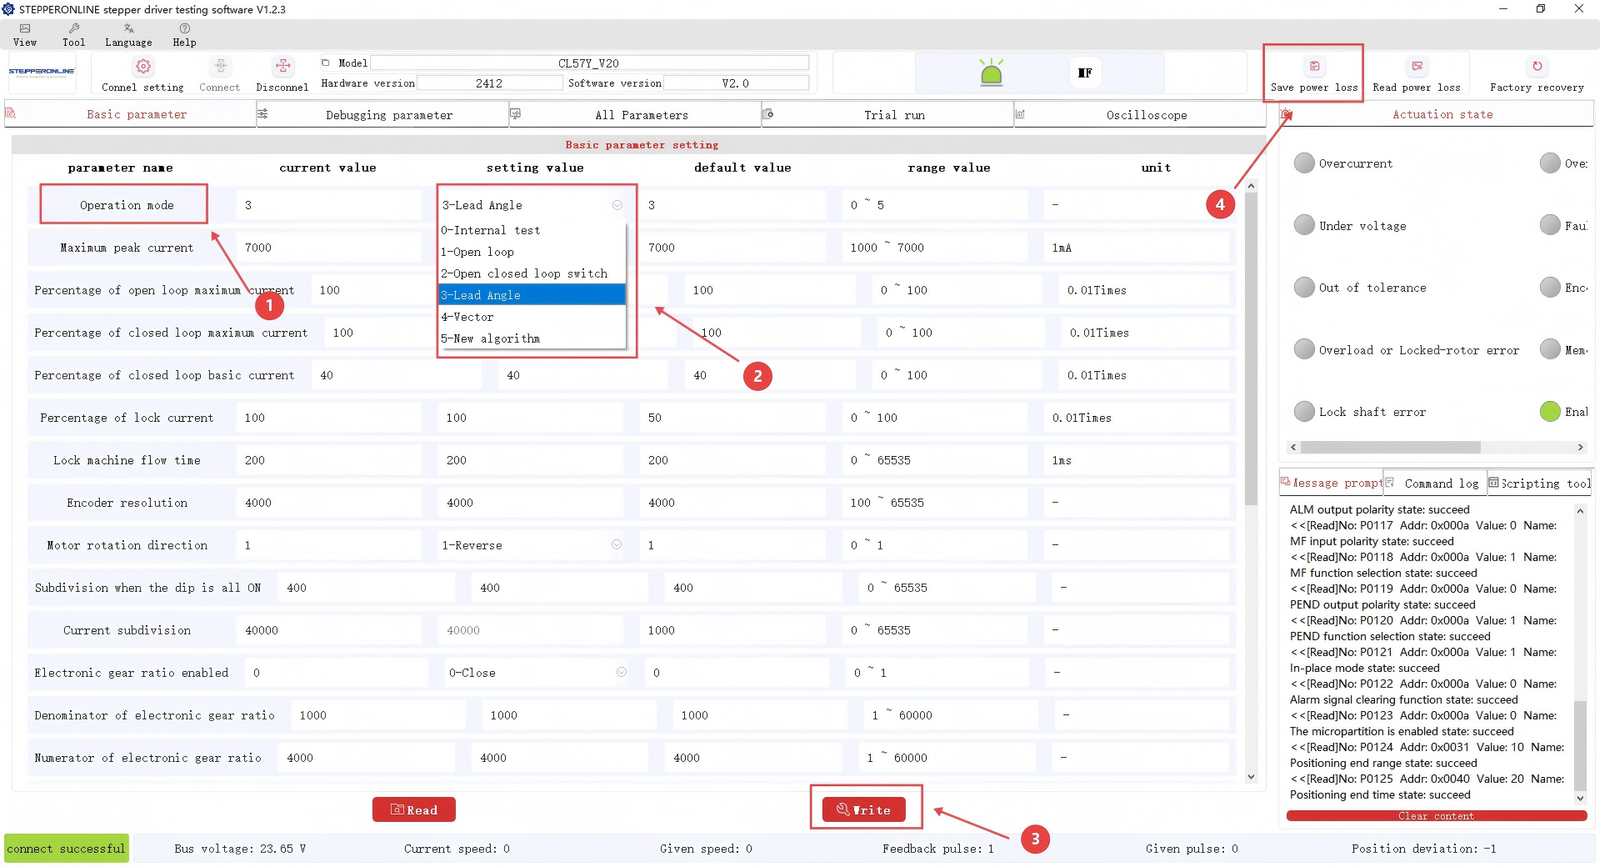
The driver supports multiple operating modes. To switch to Open-Loop mode or another mode, follow these steps:
- Locate the "Operating Mode" parameter.
- Click the dropdown menu and select the desired mode. (For explanations of each mode, refer to: Difference Between Lead-Angle Algorithm and Vector Mode Algorithm in Y Series Closed-Loop Driver Operating Modes)
- Click "Write".
- Click "Save".
After completing the above steps, power cycle the driver (turn it off and then on again) for the mode change to take effect.
- Peak Current Parameter Modification
The Y Series Closed-Loop Driver features intelligent current adjustment. Regardless of the rated current of your NEMA 23/24 motor, the driver automatically identifies the required current and outputs the optimal value.
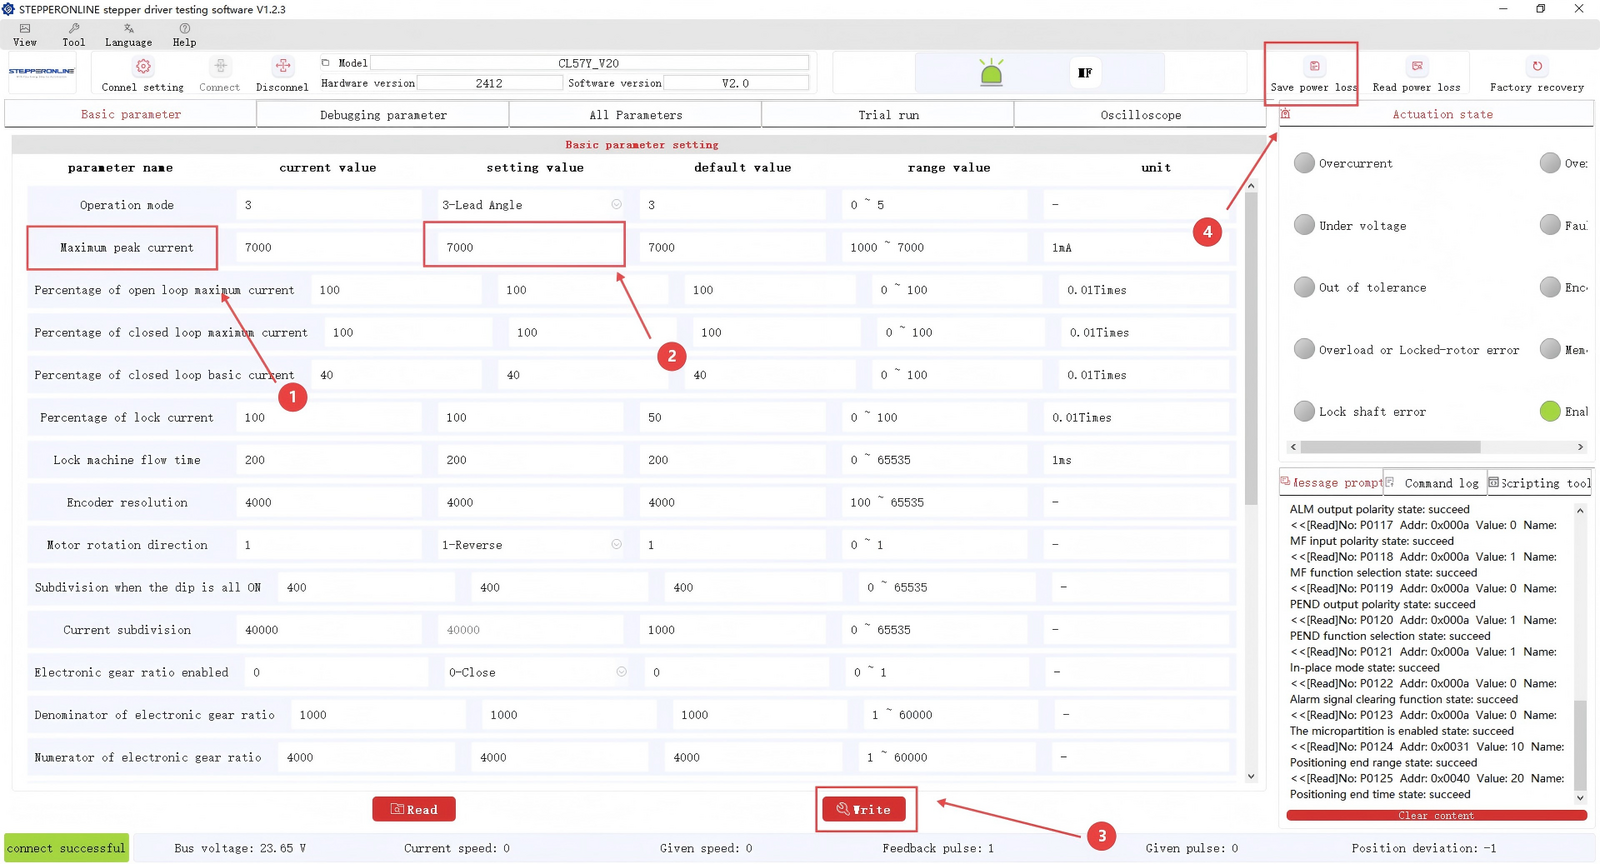
If the auto-adjusted peak current is too high or too low for your application, you can manually change it using the steps shown in the diagram above. After modifying the current parameter, be sure to click "Write" first, then click "Save", and finally power cycle the driver for the changes to take effect.
- Encoder Resolution Modification
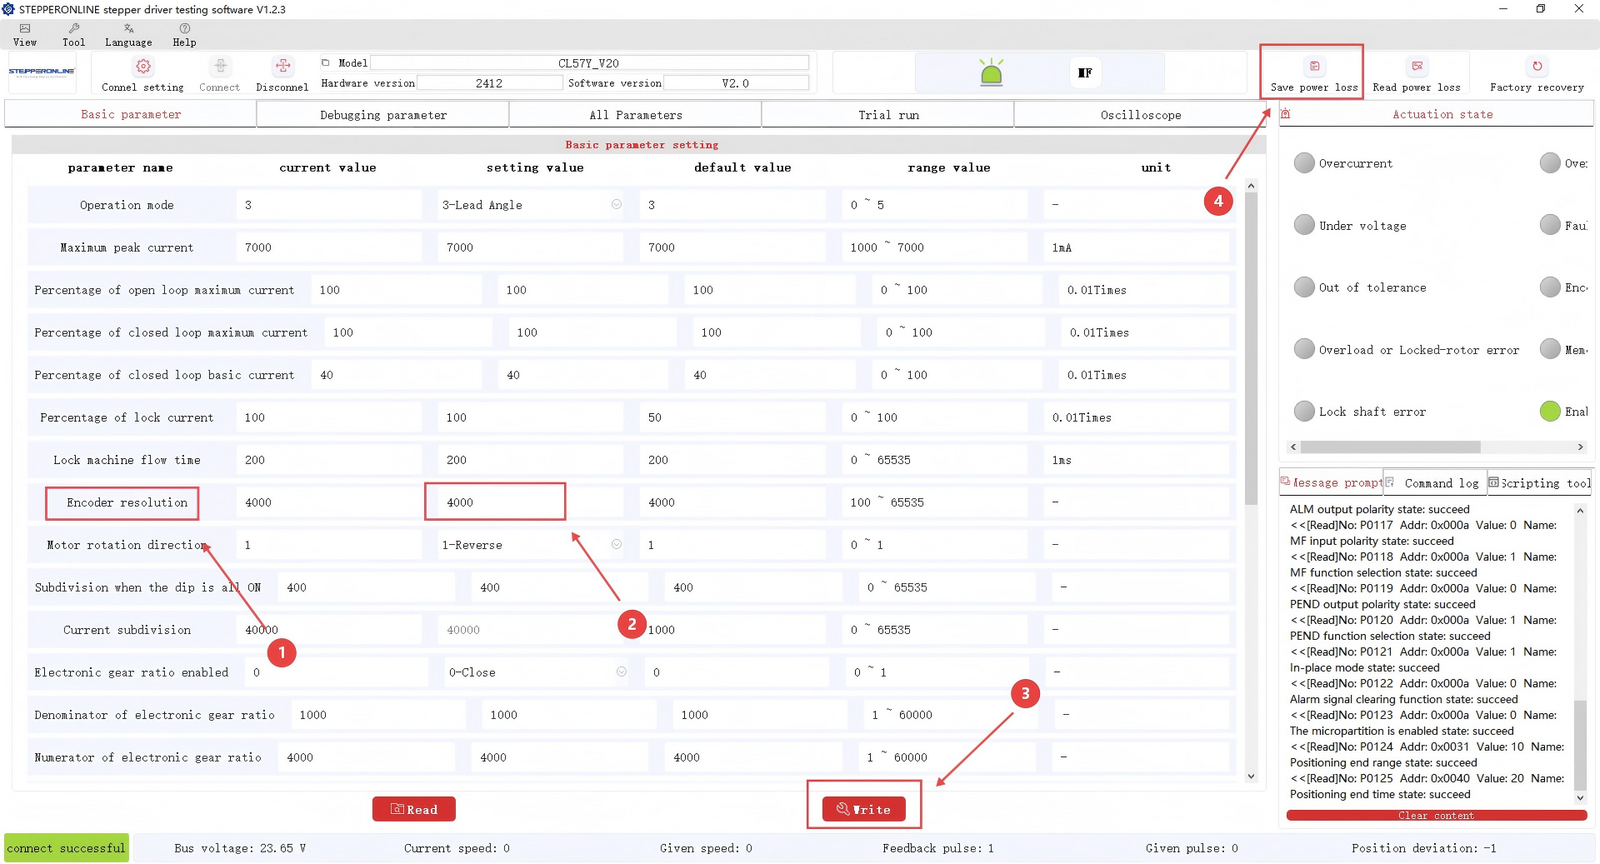
The driver natively supports encoders with a resolution of 1,000 lines (1,000 PPR). If you need to drive a motor with a different encoder resolution, modify the setting as follows:
- Locate the "Encoder Resolution" parameter.
- Enter the required encoder resolution value. (The unit displayed here is CPR. 1,000 PPR = 4,000 CPR.)
- Click "Write".
- Click "Save Parameters".
Finally, power cycle the driver for the changes to take effect.
- Gain Adjustment
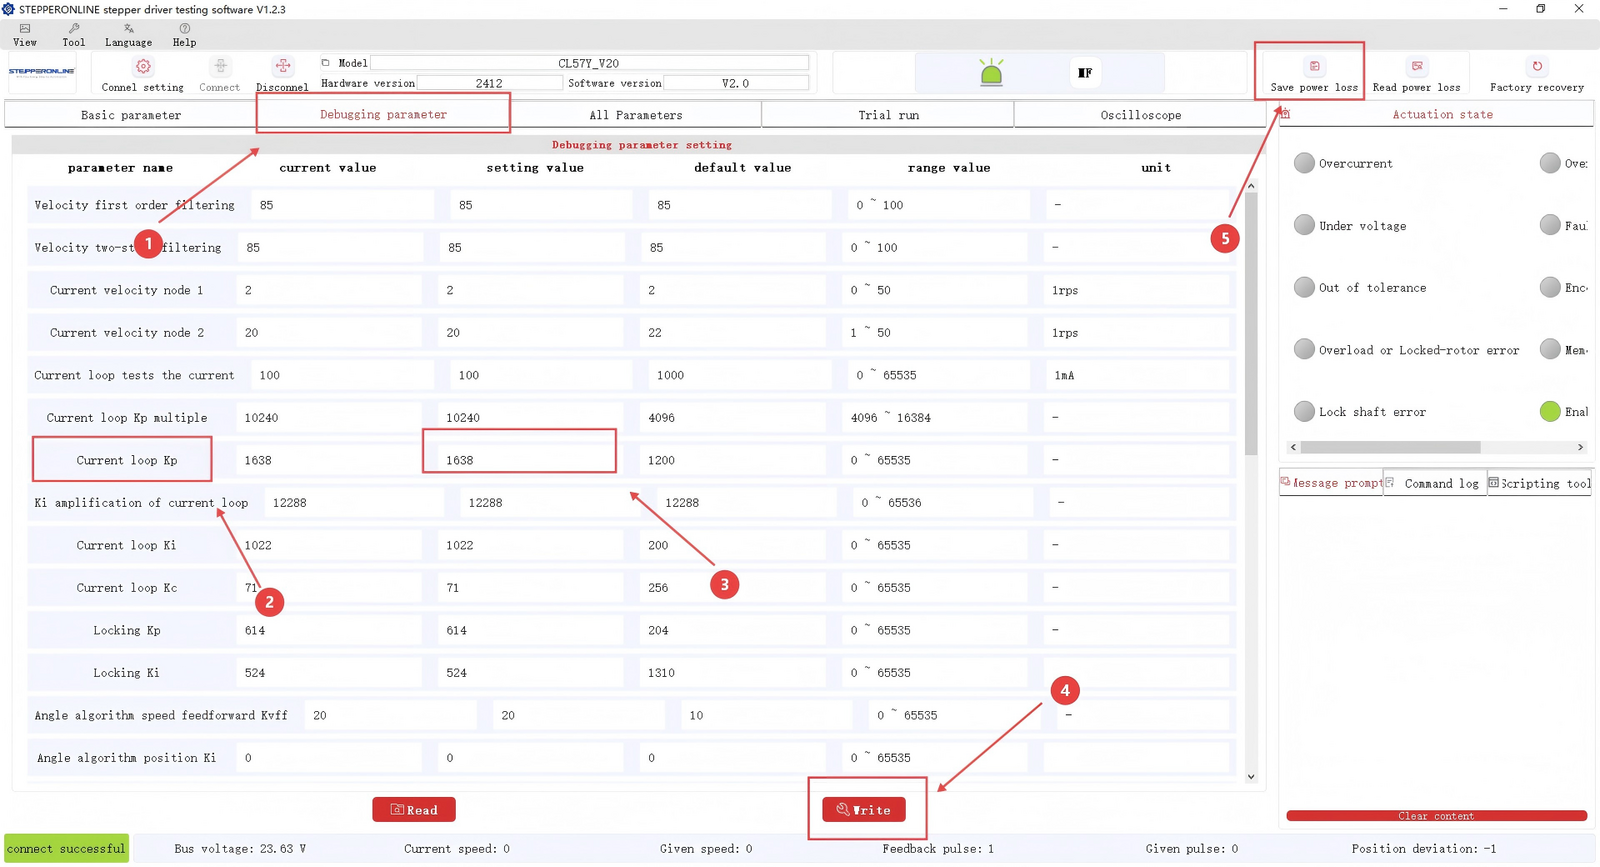
Adjusting the gain parameters can help reduce excessive motor noise. Locate the "Current Loop" parameters and modify them according to the following guidelines:
- For heavy loads or high-speed operation: increase the value by 100 increments from the default setting.
- For light loads or low-noise priority: decrease the value by 100 increments from the default setting.
After modification, click "Write" and then "Save Parameters".
- Internal Test / Trial Run Function
The driver includes a built-in self-test mode (Trial Run) that allows you to control the motor using the driver's internal pulse generator, without requiring an external controller. This function is useful for verifying that the motor and driver are operating correctly, helping to isolate issues from the external controller. The steps are as follows:
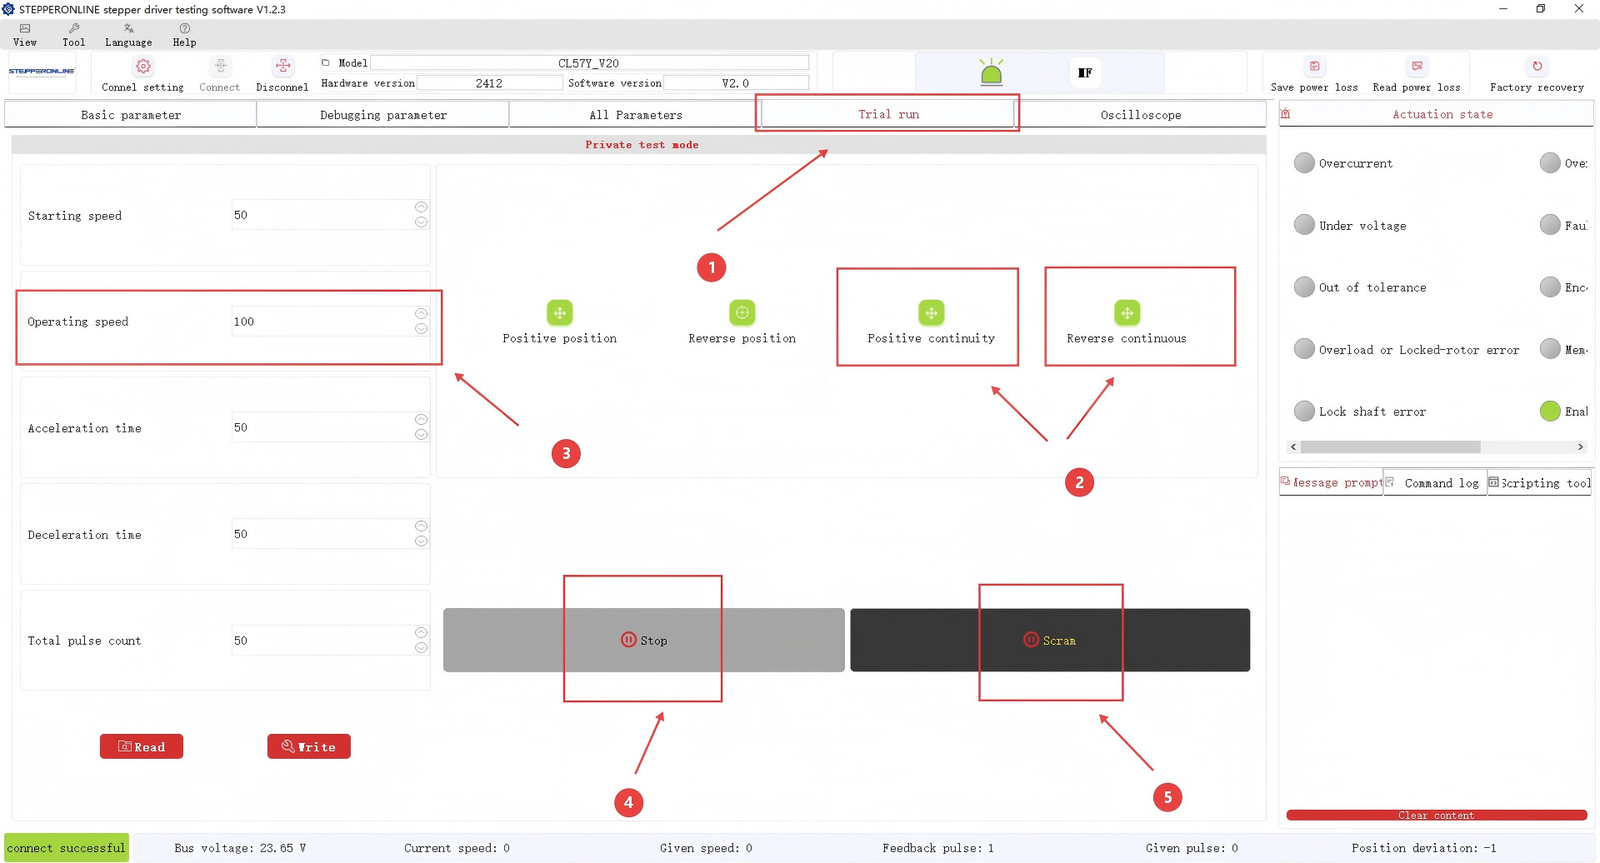
- Select "Trial Run".
- Click the "CW Continuous" or "CCW Continuous" button. The motor will start running at the speed set in step 3.
- To stop the motor, click either button 4 or button 5. Button 4 performs a controlled deceleration stop based on the configured deceleration time, while button 5 performs an immediate emergency stop.
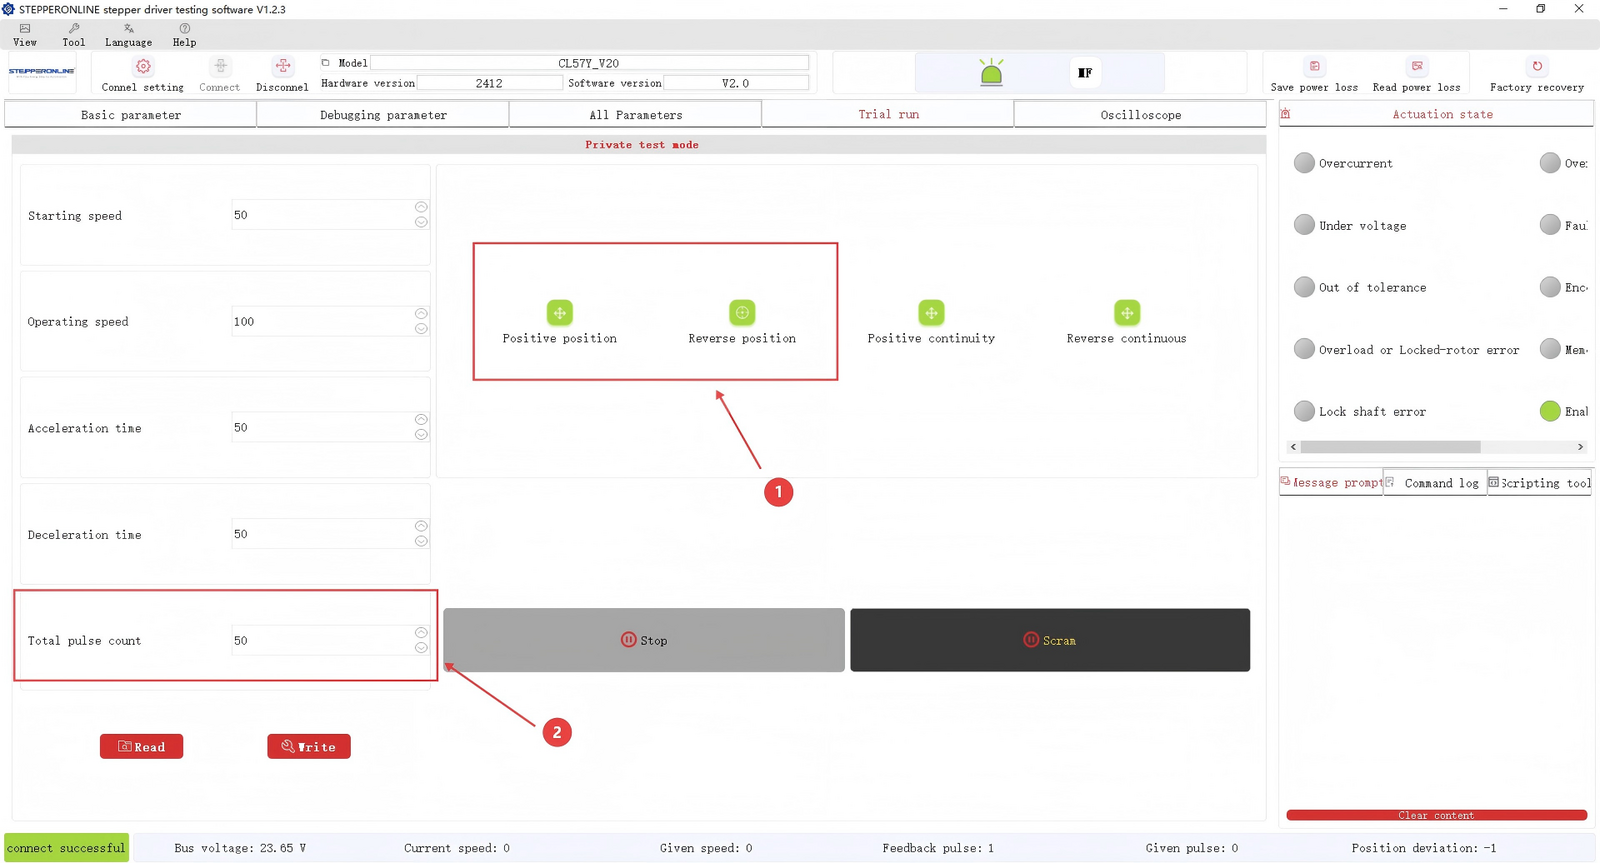
Click the "CW Position" or "CCW Position" button to send a specified number of pulses (set in step 2) to the driver, causing the motor to rotate to a target position.
For example, if the driver's microstep resolution is set to 1,600 microsteps/rev and you enter 1,600 pulses in the pulse count field, clicking "CW Position" will rotate the motor exactly one full revolution.
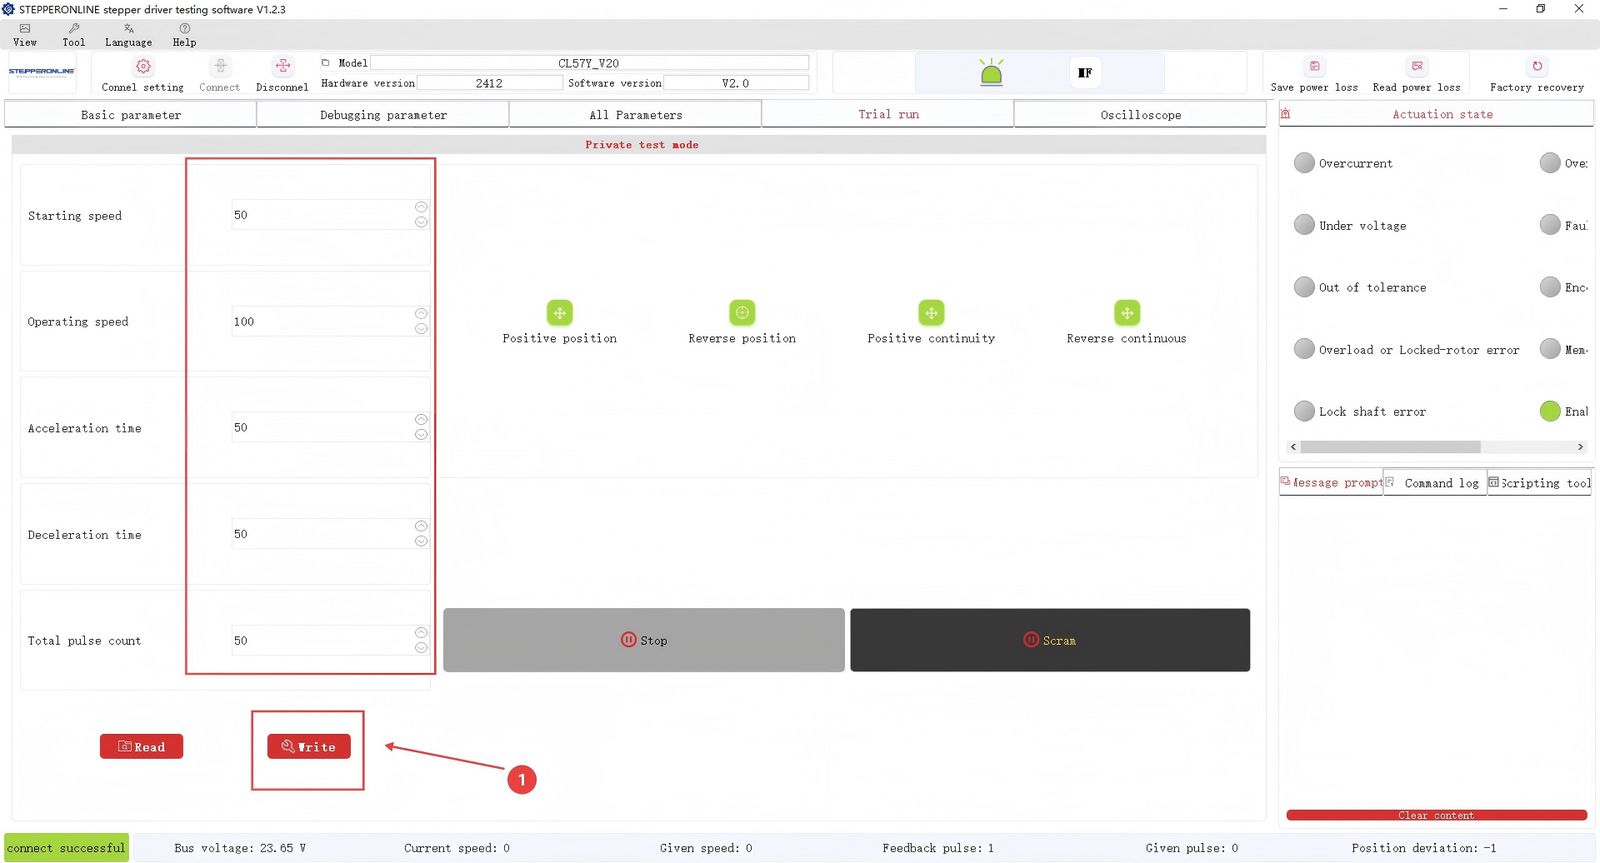
After modifying the Trial Run parameters, click "Write" to apply them. There is no need to click "Save" in the top-right corner for Trial Run settings.
The steps above cover the most commonly modified parameters. Other parameters can be modified using the same general procedure (modify → Write → Save → power cycle). If you encounter any issues while using the software, please contact our technical support team.