This guide explains how to connect the ST-C01 controller with T6 and DSY series servo motors. By following this document, you will learn the basic hardware wiring methods.
Required Materials
- ST-C01 controller
- T6 or DSY series servo motor with separate driver
- DC 24V power supply (rated current ≥ 2A recommended)
- Connecting cables (appropriate gauge for your power supply and signal wiring)
Precautions
-
Before starting, ensure you have read and understood the datasheet for the servo motor and driver being used.
-
To prevent short circuits or other electrical faults, handle all electronic components with care.
Wiring Steps: Connecting the Servo Driver to the ST-C01
-
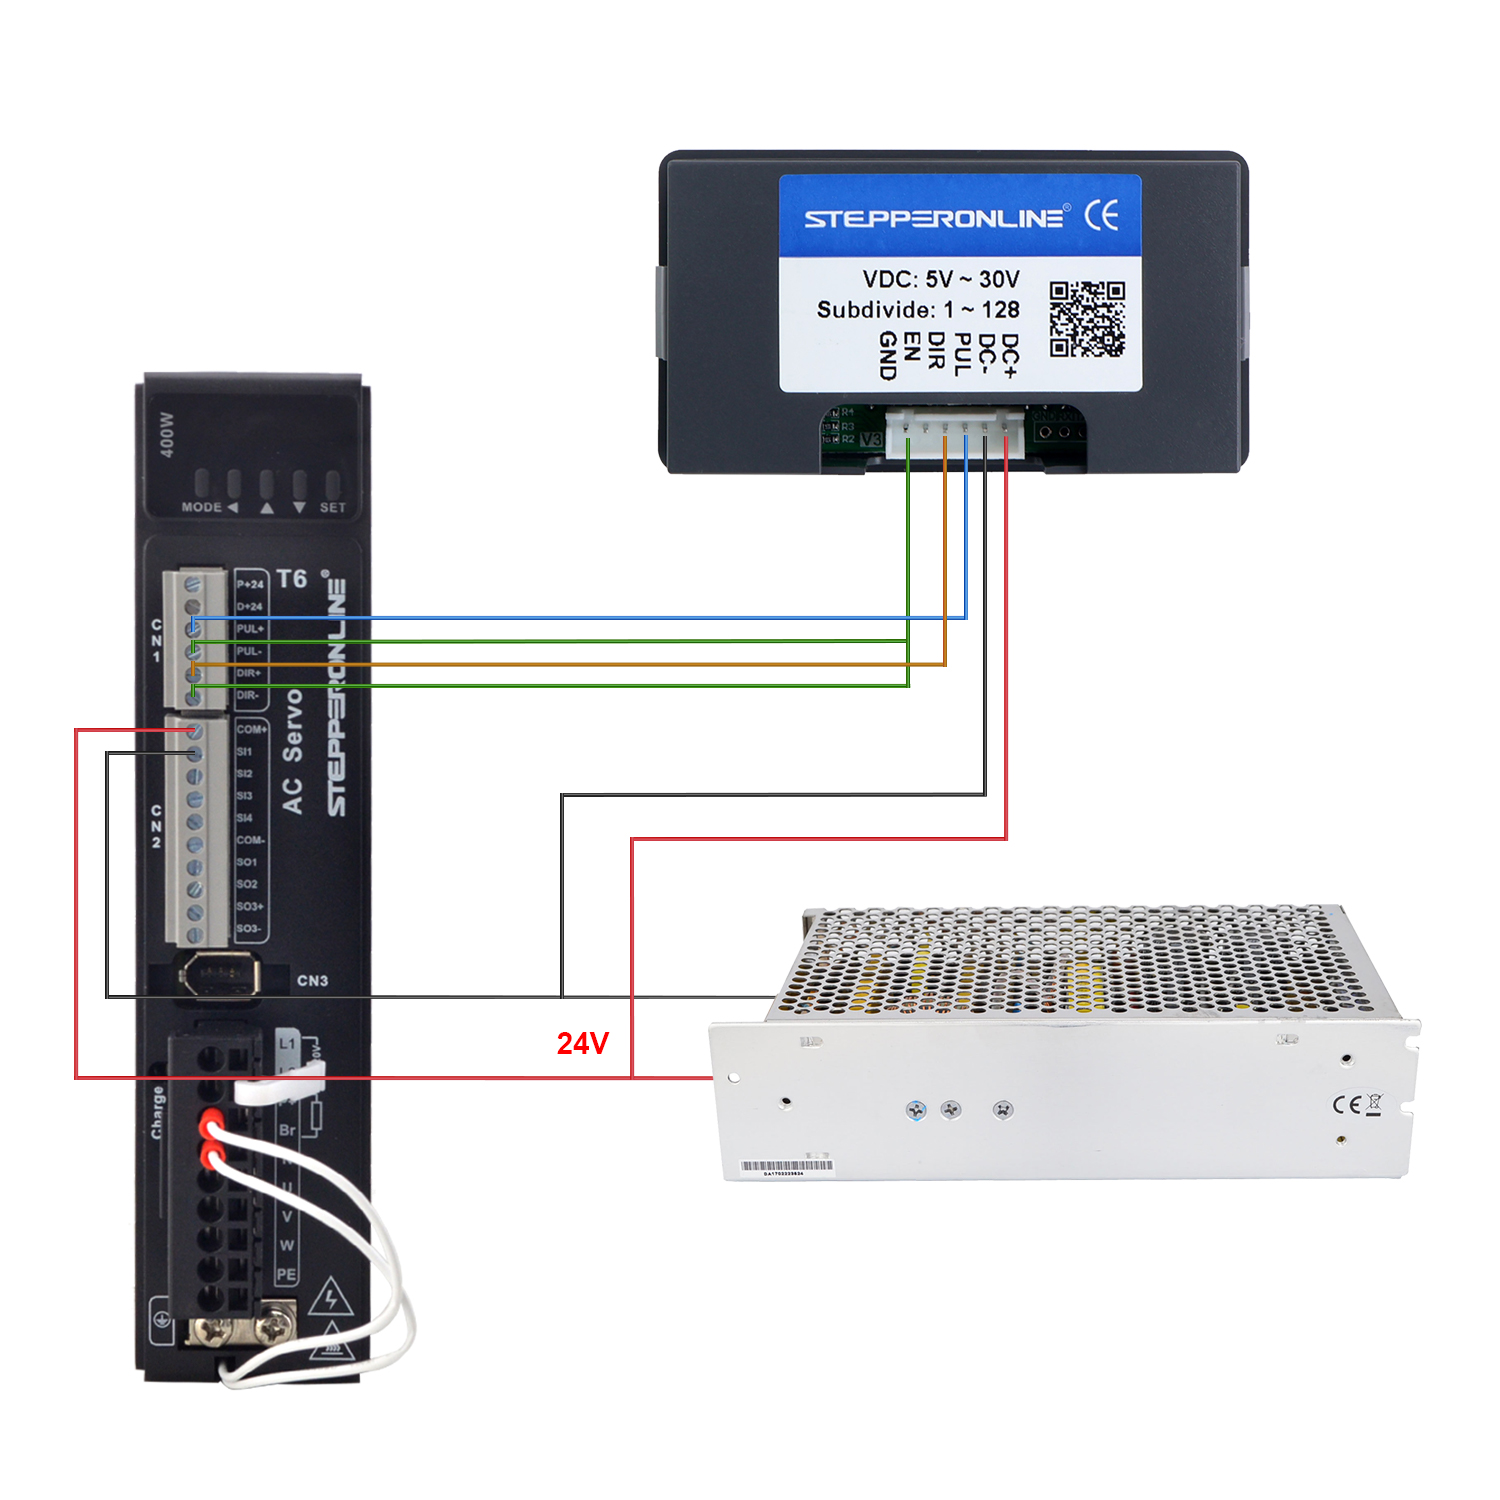
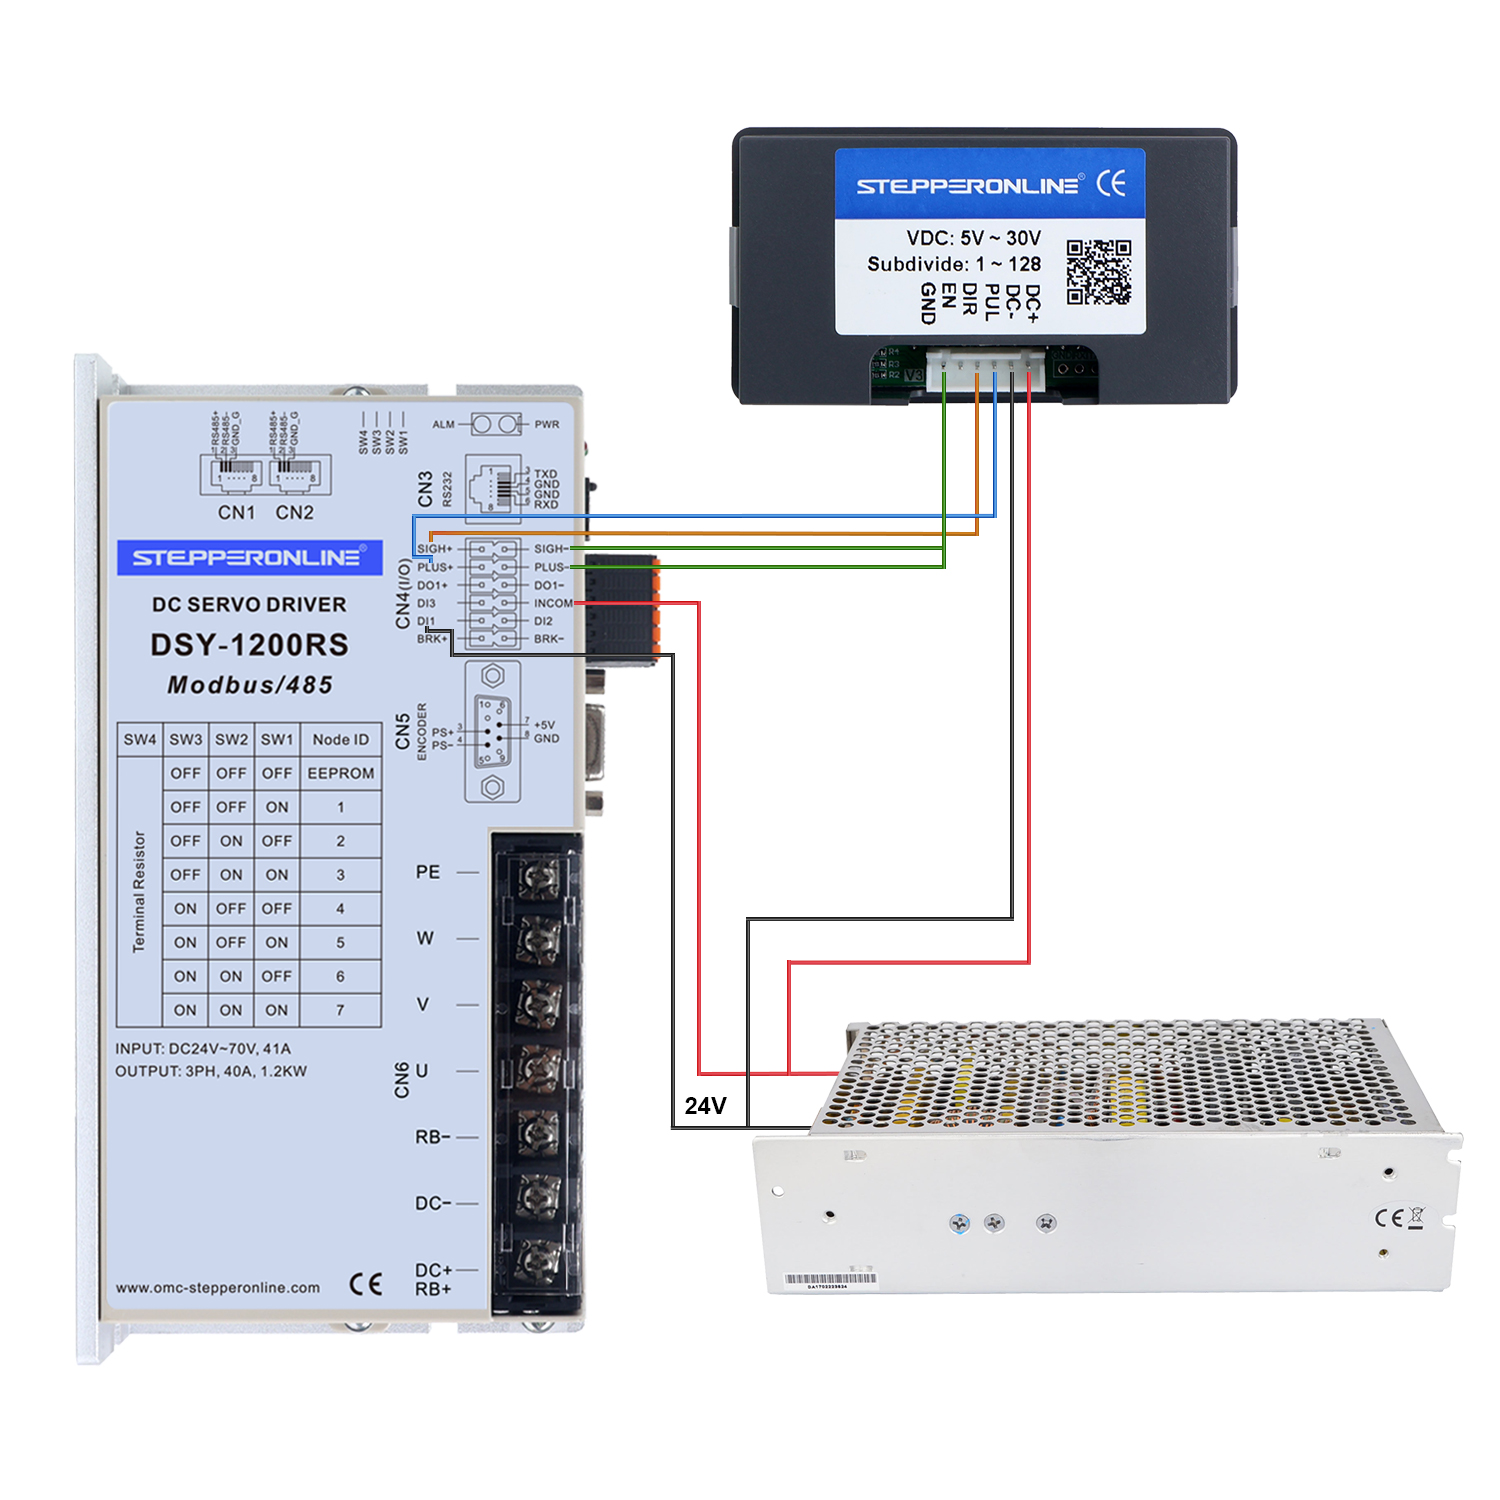
Connect the driver's DIR+ and PUL+ terminals to the DIR and PUL terminals on the ST-C01, respectively.
-
Connect the driver's PUL- and DIR- terminals to the GND terminal on the ST-C01.
Wiring Diagrams
- T6 series servo motor and ST-C01 wiring diagram
- DSY series servo motor and ST-C01 wiring diagram
Configuration Example
For detailed ST-C01 controller operation instructions, refer to the ST-C01 User Manual.
Video demonstration results:
After power-on, the motor rotates forward at 100 RPM for 1 rotation, pauses for 2 seconds, then reverses at 200 RPM for 2 rotations, pauses for 1 second, and resumes forward motion. One forward-reverse sequence counts as a single cycle, and the process stops after 3 cycles.
Parameter settings:
-
F-01 → Motion mode
-
F-02 → Forward distance (Forward rotations = F-02 ÷ pulses per revolution set on driver)
-
F-03 → Forward speed (Forward RPM = (F-03 × F-09) ÷ pulses per revolution set on driver)
-
F-04 → Reverse distance (Reverse rotations = F-04 ÷ pulses per revolution set on driver)
-
F-05 → Reverse speed (Reverse RPM = (F-05 × F-09) ÷ pulses per revolution set on driver)
-
F-06 → Cycle count (Unit: times)
-
F-07 → Forward delay time (Unit: seconds)
-
F-08 → Reverse delay time (Unit: seconds)
-
F-09 → Pulse scaling factor. Set this value to: (driver's pulses per revolution) ÷ 10. Example: If the driver is set to 1000 pulses/rev, set F-09 = 100.
Note: The ST-C01 has limited functionality and is designed for basic speed and position control tasks. For more advanced control, consider using an Arduino-based solution—refer to our related wiring guides for more information.