This article describes how to configure the PR (Positioning Routine) function on the T6 servo drive to perform homing with limit switch detection.
Hardware
- T6 servo drive and servo motor
- DC 24V switching power supply
- Switches
Function Description
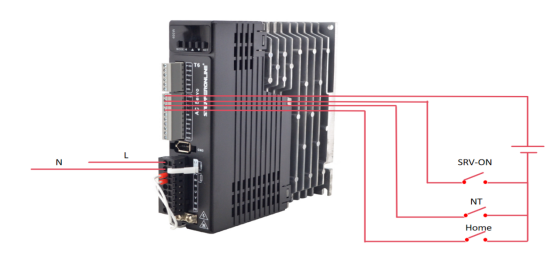
The SRV-ON (servo enable) signal is input through the SI1 terminal, the negative limit signal is input through the SI2 terminal, and the home signal is input through the SI3 terminal. This configuration enables homing with limit switch detection.
How to Implement the Function
- Set the following parameters: Pr0.01 = 6, Pr8.10 = 0, Pr4.02 = 21, Pr4.01 = 26, Pr4.00 = 3.
- Power off the T6 servo drive. Connect the DC 24V power supply and wire the switches to the SI1, SI2, and SI3 terminals as shown in the diagram below. Then power on the drive for testing.
- Before running the motor, activate the SRV-ON signal on the SI1 terminal.
- Trigger the home switch connected to the SI3 terminal. The motor starts to run. When it triggers the negative limit switch on the SI2 terminal, it decelerates, reverses direction, and stops. This stop position is defined as the home position.
Homing is complete. The motor has reached the home position.